Timo Lüddecke
Research Group Leader
Institute of Computer Science
University of Göttingen
I develop machine learning methods for computer vision that learn efficiently from limited data and labels, with a focus on dense prediction, multi-modal learning, and extending foundation models. Current directions include spatiotemporal and 3D/4D understanding and making strong vision backbones accessible through lightweight, data-efficient readouts. Much of my work is interdisciplinary, including primate behavior analysis, vibroacoustic engineering, remote sensing, and neuroscience.
Group Members
- Jan van Delden (PhD student)
- Felix B. Müller (PhD student)
- Jan Meier (PhD student)
- Christian Libner (PhD student)
- Diego Canez (incoming PhD student)
Former Members
- Julius Schultz (associated PhD student at TU Braunschweig)
Short Bio
Before starting my research group in January 2024, I worked as a postdoc with Alexander Ecker. I completed my PhD in 2019 with Florentin Wörgötter working on robotic perception at the University of Göttingen. I received Bachelor and Master from the University of Magdeburg with an emphasis on medical image processing working with Klaus Tönnies.Selected Publications
See Google Scholar for an up-to-date and complete list of publications.
TrAction: Action Recognition with Sparse Trajectories
NeurIPS 2026
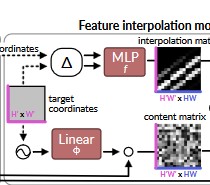
LiDeRe: A Lightweight Readout for Fast and Data-Efficient Dense Prediction
Conference on Computer Vision and Pattern Recognition (CVPR) 2026
PriVi: Towards a General-Purpose Video Model for Primate Behavior in the Wild
Conference on Computer Vision and Pattern Recognition (CVPR) 2026
Detection transformer-based approach for mapping trees outside forests on high resolution satellite imagery
Ecological Informatics 2025


An unsupervised map of excitatory neuron dendritic morphology in the mouse visual cortex
Nature Communications, 2024



One-shot multi-path planning for robotic applications using fully convolutional networks
International Conference on Robotics and Automation (ICRA), 2020


Distributional Semantics of Objects in Visual Scenes in Comparison to Text
Artificial Intelligence, 2019

Context-based Affordance Segmentation from 2D Images for Robot Action
Robotics and Autonomous Systems (RAS), 2019

Learning to Segment Affordances
International Conference on Computer Vision Workshops (ICCVW), 2017

Convolutional Neural Networks for Movement Prediction in Videos
German Conference on Pattern Recognition (GCPR), 2017

Open Source Software

DrawCNN
DrawCNN is a python script to visualize CNN architectures and export to SVG for later refinement.
